

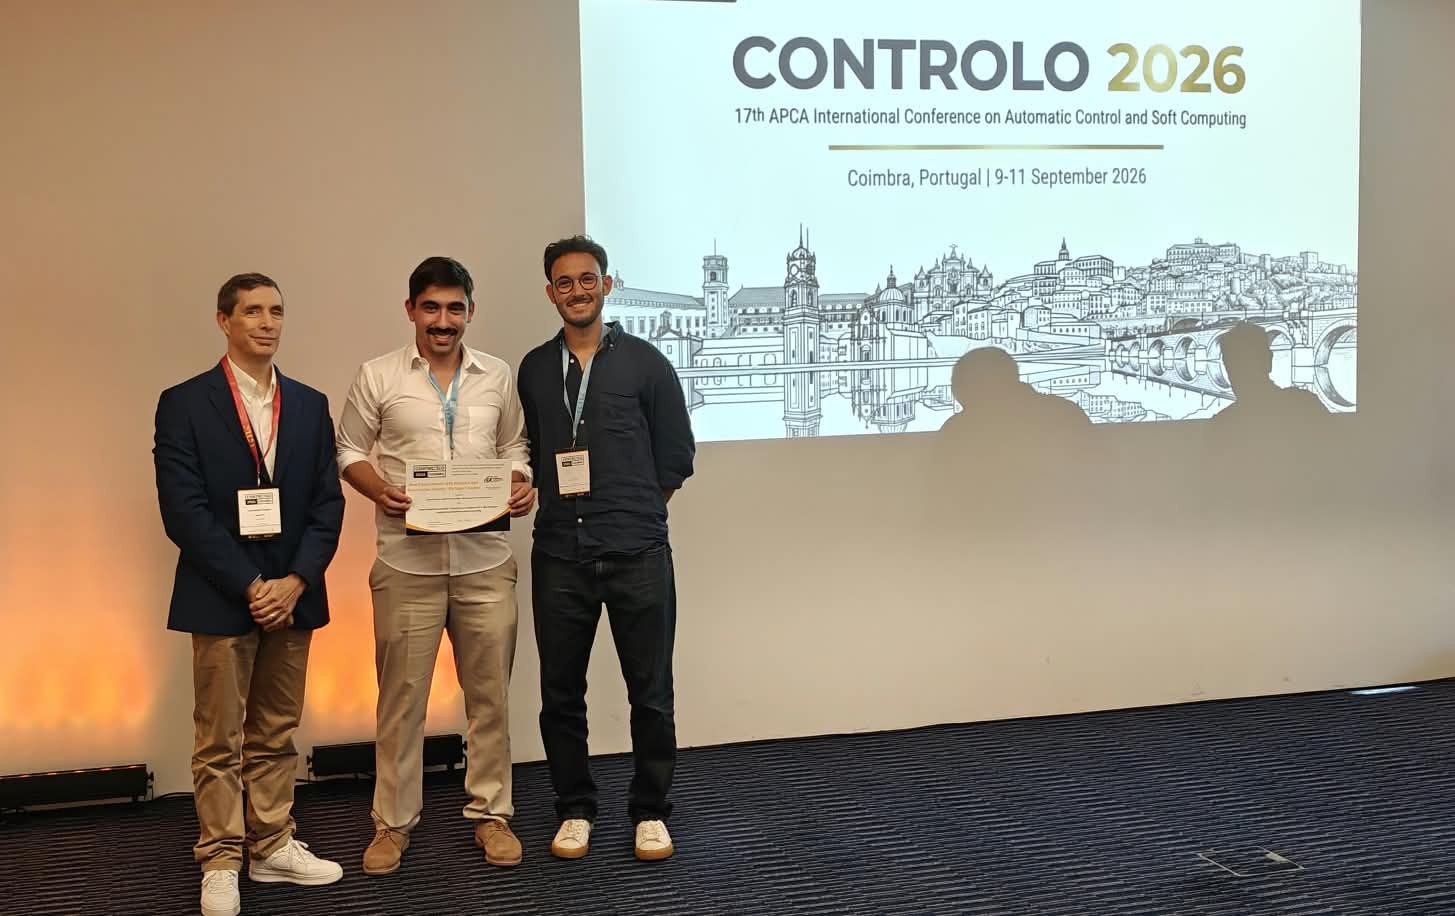
Research promoting robot autonomy using Artificial Intelligence has received the Best Paper Award from the IEEE Robotics and Automation Society (RAS) – Portugal Chapter – at the APCA International Conference on Automatic Control and Soft Computing (CONTROLO 2026).
The work Vision-Based Landmark Tracking and Guidance of a Quadcopter using Deep Reinforcement Learning was developed by researchers from SYSTEC in collaboration with Armando Sousa – INESC TEC researcher specialising in robotics, and professor at the Faculty of Engineering of University of Porto. The research addresses vision-based autonomous navigation and guidance of a mini-drone using deep reinforcement learning techniques.
In particular, the research explores the use of said techniques to enable a nano-quadcopter (Crazyflie) to perform tracking and guidance tasks autonomously, based on the visual information available.
According to Armando Sousa, “the collaboration on this work represents an opportunity to explore the application of advanced Artificial Intelligence and reinforcement learning techniques in real-world robotics”. The researcher, who co-authored the paper with Conrado Guimarães da Costa, Gabriel M. Fernandes and Rui Carvalho da Costa, from SYSTEC, said that the award “highlights the relevance and scientific quality of the work developed, as well as the importance of collaboration between SYSTEC and INESC TEC in the fields of robotics, autonomous systems and control engineering”.
Held in Coimbra from 9 to 11 September, the 17th edition of CONTROLO brought together researchers and professionals from around the world to share advances in control systems, automation and robotics, as well as applications of soft computing.
 News, current topics, curiosities and so much more about INESC TEC and its community!

